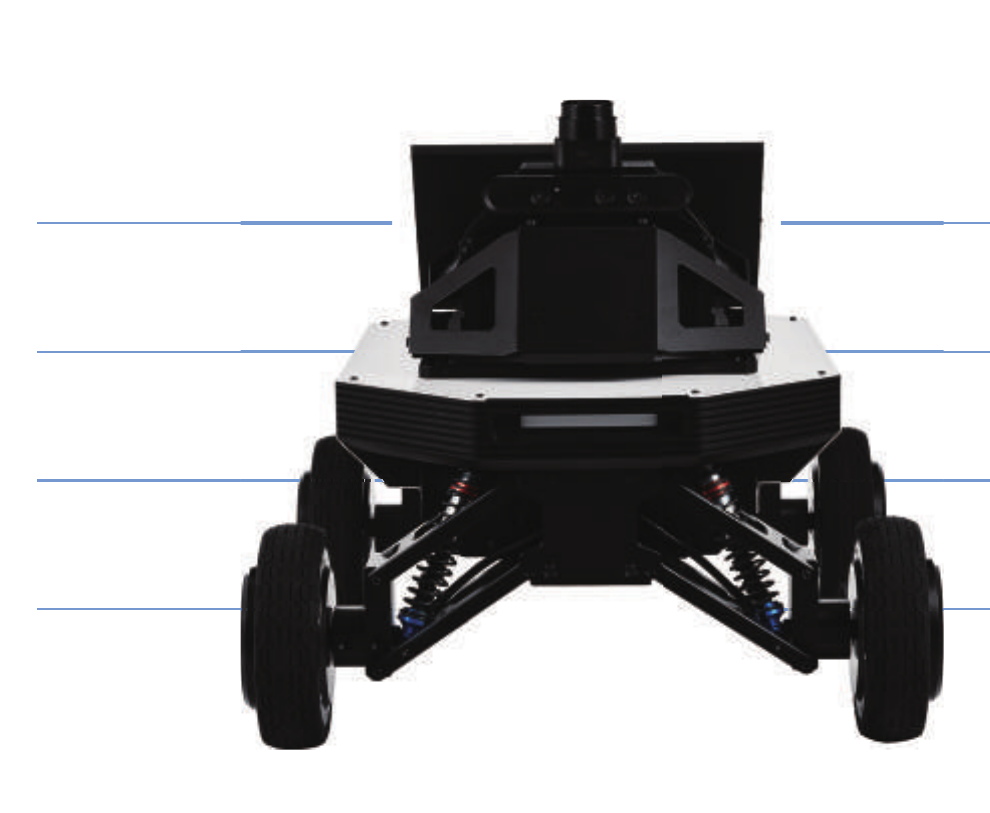
ROS Modular Robot

A mobile base
with a robotic arm.

PadBot E2 pairs a navigating mobile platform with a robotic arm, built for grasping, manipulation and perception research.

Robotic armROS / Python / C++Deep-learning perception
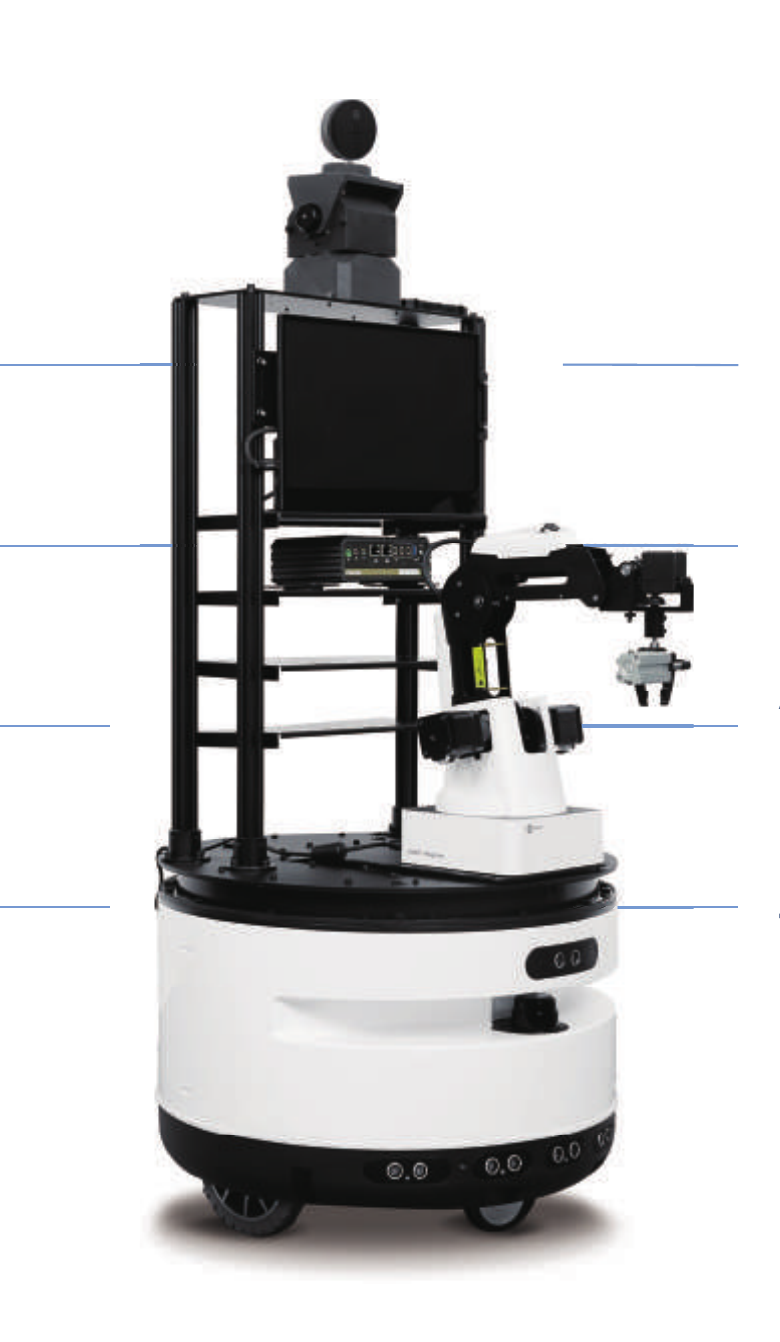
PadBot E2

Modular platform

Rapid construction of custom robot systems.

Navigation & positioning

Autonomous movement with obstacle avoidance.

Application functionality

Vision, NLP and edge-computing perception.

Open development tools

ROS interfaces, Python and C++ SDKs.
How it works

Three steps to put it to work

STEP 01

Mount your payload

Modular platform supports arms, sensors and cameras.

STEP 02

Navigate and grasp

Moves autonomously, then manipulates objects.

STEP 03

Build with open tools

ROS interfaces, Python and C++ SDKs.
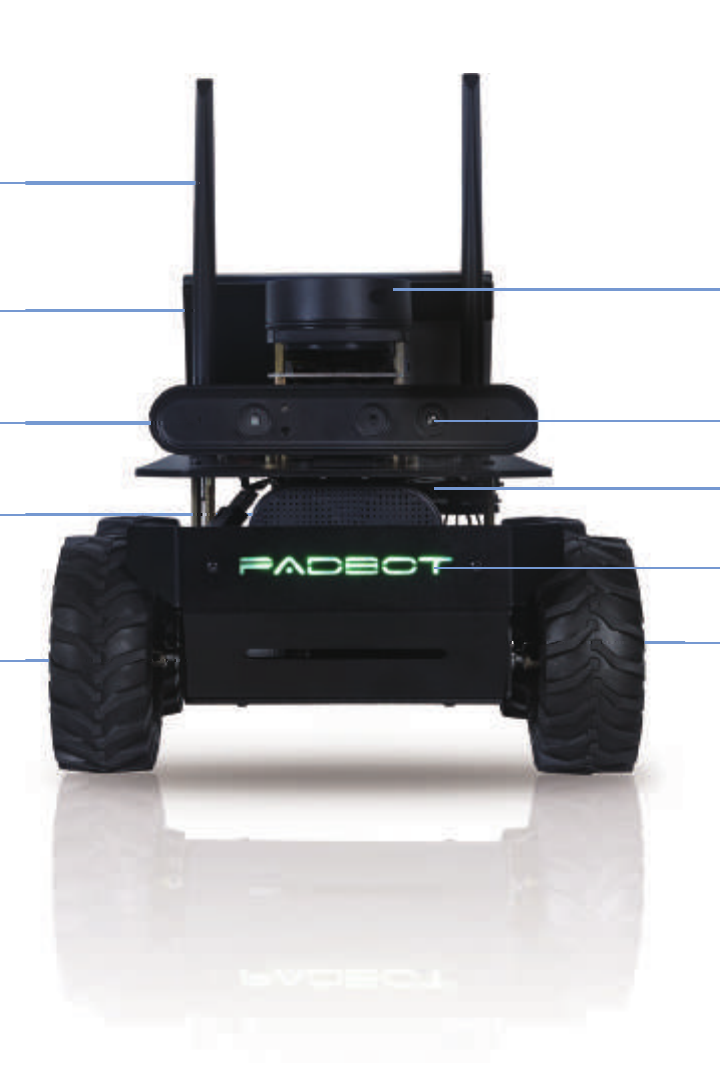
Specifications

Technical specs

Size (WxHxL)50x60x125 cm
Weight32 kg
Speed0.7 m/s
Running time10 h
Charging time9 h
Navigation area≤20,000 m²
Where it works

Built for these environments

Research roomLaboratory
You might also like

More Education & Research Robots

Ready when you are

Let's find the right fit for your site.

Tell us about your space and we'll come back with pricing, lead times and a tailored recommendation.